Keynote Speakers
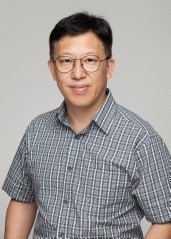
Prof. Xinheng Wang
Xi'an Jiaotong-Liverpool University, China
Biography: Prof. Wang was the founding Head of Department of Mechatronics and Robotics. He is an IET Fellow and a senior member of IEEE. He is also a team leader of Talented Jiangsu Innovation and Entrepreneur Programme. He has broad academic working experience in China, England, Wales, and Scotland for more than 20 years. He has extensive research experience in Internet of Things (IoT), wireless mesh networks, indoor positioning, big data analytics, and applications for smart cities. Along with more 30+ research projects sponsored from the EU, UK EPSRC, Innovate UK, China NSFC, and industry, his research in each area has led to an impactful industrial product. For example, the smart trolley, which has been deployed at more than 30 airports in China, he has developed with industrial partner is the first in the world to provide an IoT solution aiming at providing intelligent airport services for passengers. His collaborative research in acoustic localisation with Prof. Zhi Wang at Zhejiang University has won the first place in Microsoft Indoor Localisation Competition in sound group. He has 260+ publications and filed dozens of patents, including 6 granted patents in the US, Japan, and South Korea, and 18 granted patents in China. His research had been classified as World Leading at the UK's REF assessment. The highest citation number of a single technical paper on Google Scholar is over 700. Overall citation is over 6000 with an h-index of 35. He is currently leading a university-industry collaborative research centre XJTLU-uGo Robotics Research Centre with sponsorship from industry of multi-million yuan to develop robots for passenger services and airport services. To this end, some significant achievements have been made, including a Deep SLAM and Navigation system where accuracy of localization could reach 3 cm in real-world applications and response time for path planning could be reduced to milli-second level from dozen of seconds. In addition, robots can recognise glass accurately and operate in environments with glass without any difficulty. Apart from research in robotic SLAM and navigation, his other research interests include intelligent manufacturing and healthcare. In intelligent manufacturing, he is investigating a system dubbed as VisionTwin to integrate industrial Internet of Things (IIoT), edge computing, machine vision, digital twin, and artificial intelligence to promote the intelligence of manufacturing. One application example is condition monitoring of overhead power lines, where a 3-dimensional space could be created on a typical 2D camera. In healthcare, he has led a team to develop a novel application of diagnosing COVID-19 on smartphones by monitoring users' breathing. In addition, he is investigating technologies for motion and posture detection of users indoors by acoustic analysis on smartphones.
Speech Title: Exploration and Perception of Service Robots in Complex Indoor Environments
Abstract: Service robots, such as cleaning robots used at households, food delivery robots used in restaurants, good delivery robots used in industry and human-following robots in large public spaces, are widely used to support our community. These robots are mostly operating in indoor environments successfully. However, in some complex indoor environments, such as airports with a large amount of glass, it remain a serious challenge for the robots to operate freely. Recently, some breakthroughs were made for the detection and recognition of glass. This report will share the latest development of glass segmentation for service robots in large complex indoor environments.
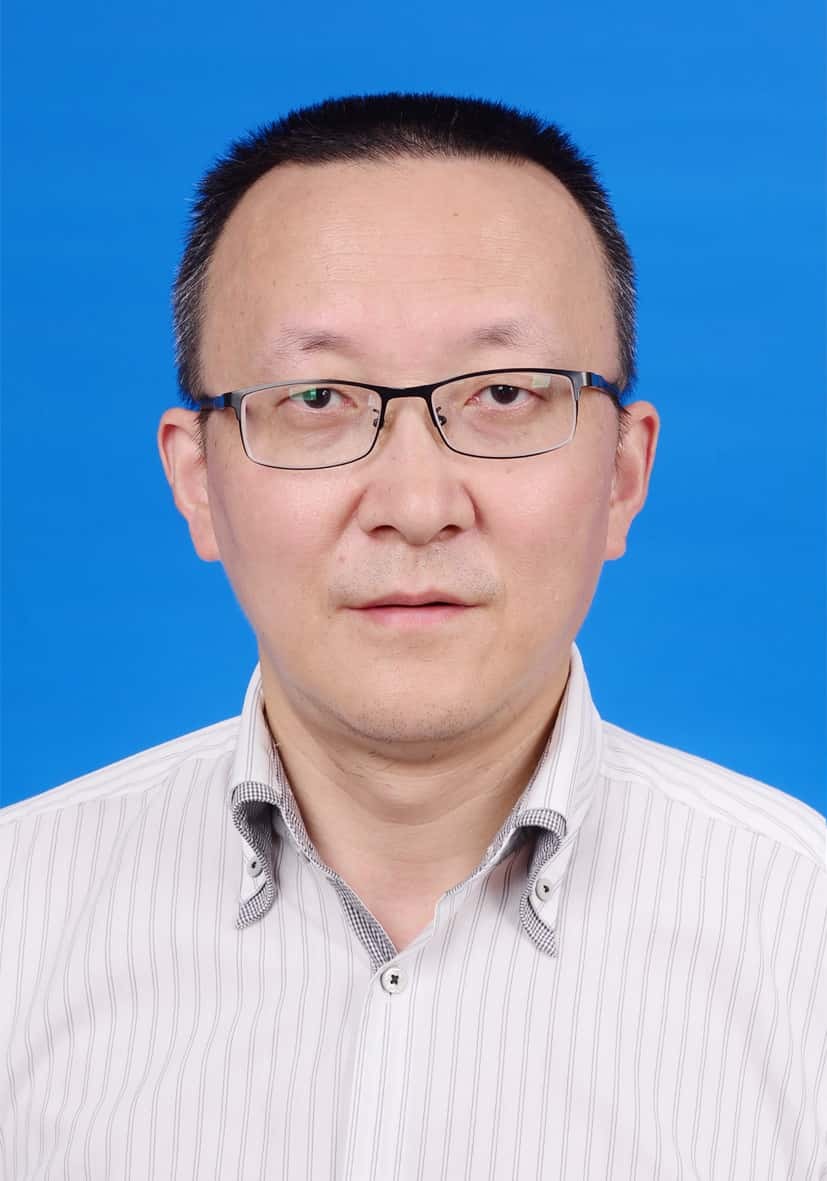
Prof. Juntao Fei
Hohai University, China
Biography: Juntao Fei is now a professor (Level II) at Hohai University, Life Fellow of IAAM, Senior Member of IEEE. He received his M.S and Ph.D. degree from the University of Akron, USA. He was visiting scholars at University of Virginia, USA, North Carolina State University, USA respectively. He ever served as an assistant professor at the University of Louisiana, USA. He has led more than 20 projects . He published over 200 SCI-indexed papers, among which 25 are ESI Highly Cited Papers and 4 are Hot Papers. He holds over 100 authorized invention patents and published 5 monographs. He currently serves as an Associate Editor for four SCI-indexed journals. He has been recognized as a Highly Cited Chinese Researcher by Elsevier, a top 0.05% scholar by ScholarGPS, and a top 2% scientist by Stanford University. His current research interests are neural network, artificial intelligence, mechatronics and robotics.
Speech Title: Fuzzy Neural Network Complementary Sliding Mode Control of Active Power Filter
Abstract: In this speech, a complementary sliding mode controller using a self-constructing Chebyshev fuzzy recurrent neural network (SCCFRNN) is proposed for harmonic suppression control of an active power filter . The SCCFRNN whose structure can be automatically learned through the designed structure self-learning algorithm is introduced to approximate the unknown nonlinear term in APF dynamic model, so as to improve modeling accuracy and reduce the burden of complementary sliding mode control. The SCCFRNN, combines the advantages of fuzzy neural network (FNN), recurrent neural network and Chebyshev neural network, and all parameters can be adjusted according to the designed adaptive laws. Both the simulation and experimental comparisons illustrate the feasibility and superiority of the proposed control algorithm under different test conditions.
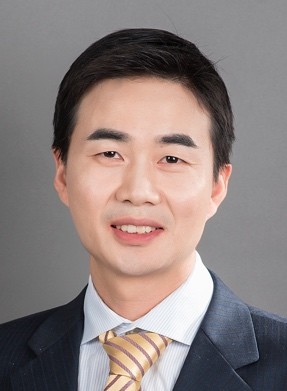
Prof. Zhigang Wu
Huazhong University of Science and Technolog, China
Biography: Zhigang Wu is a dual-appointed professor at Huazhong University of Science and Technology and Shenzhen Loop Area Institute. His research focuses on embodied intelligence, AI-driven intelligent design, and manufacturing. He has published over 100 academic papers in international journals such as Sci Rob、Sci Adv、Nat Comm、Adv Mater、Natl Sci Rev, with a total of over 6000 citations. His paper was selected as a best paper at the IEEE ICRA 2024, and he was selected as a high-contribution author by Wiley in 2025. He is also serving as an editorial member in several journals such as JMM, Micromachine, AI for Engineering, and as an associate editor for IEEE Transactions on Soft Robotics.
Speech Title: Soft Technologies Meet Artificial Intelligence: The New Frontier of Embodied Intelligence
Abstract: Large language models, multimodal models, and vision-language-action systems are extending artificial intelligence from understanding and generating information toward perceiving, reasoning, deciding, and acting in the physical world. In this transition from digital intelligence to embodied intelligence, AI is providing increasingly powerful capabilities for perception, learning, reasoning, and decision-making, while soft technologies, such as soft robots, compliant structures, soft sensing, and adaptive materials, provide a distinctive physical foundation for embodied intelligence. Their deformability, compliance, adaptability, and rich physical interactions enable robots to engage with uncertain, dynamic, and unstructured environments safely. Thus, the convergence of artificial intelligence and soft technologies offers an unbounded space for imagination. In this talk, we present our efforts on how to fuse these two frontiers and the challenges during the process.
Assoc. Prof. Xiang Li
Tsinghua University, China
Biography: Xiang Li is an Associate Professor (with tenure) with the Department of Automation, Tsinghua University. His research interests include robotic dexterous manipulation and medical robots. He has published three monographs distributed by Springer and Elsevier and authored over 100 papers in the field of robotics, including publications in IJRR, TRO, ICRA, and IROS. He received the IROS Best Application Paper Finalist in 2017, the ICRA Best Medical Robotics Paper Finalist in 2024, the RAL Outstanding Associate Editor in 2025, and the TASE Best AE Award in 2026. He led the team and won the first place at 2024 ICRA Robotic Grasping and Manipulation Challenge – in-hand track and also the Most Elegant Solution across all the tracks. He has been the Associate Editor of IEEE TASE since 2023, the Associate Editor of IJRR since 2024, the Associate Editor of IEEE TRO since 2025, and the Senior Editor of IEEE RAL since 2026.
Speech Title: A Tactile-Informed Bi-Level Framework for Robust Model-Based In-Hand Manipulation
Abstract: Robotic dexterous in-hand manipulation, where multiple fingers dynamically make and break contact, represents a step toward human-like dexterity in real-world robotic applications. Unlike learning-based approaches that rely on large-scale training or extensive data collection for each specific task, model-based methods offer an efficient alternative. However, due to the complexity of physical contacts, existing model-based methods encounter challenges in efficient online planning and handling modeling errors, which limit their practical applications. To advance the effectiveness and robustness of model-based contact-rich in-hand manipulation, this talk introduces a new integrated framework that mitigates these limitations. The integration involves two key aspects: 1) integrated real-time planning and tracking achieved by a hierarchical structure; and 2) joint optimization of motions and contacts achieved by integrated motion-contact modeling. Extensive experiments demonstrate that our approach outperforms existing model-based methods in terms of accuracy, robustness, and real-time performance.
Assoc. Prof. Qingkun Liu
Shanghai Jiao Tong University, China
Biography: Qingkun Liu is currently an Associate Professor at the School of Integrated Circuits, Shanghai Jiao Tong University. He received his Bachelor's degree from the University of Electronic Science and Technology of China and his Ph.D. from Zhejiang University. He has led several national research projects, including the National Key R&D Program and projects funded by the National Natural Science Foundation of China. His primary research focuses on micro/nanorobotics, and he has published multiple papers in top-tier journals such as Nature, Nature Materials, and Science Robotics. He also serves as an editorial board member for journals including Cyborg and Bionic Systems.
Speech Title: Integrated and Intelligent Microrobots
Abstract: Integrated circuit technology combined with functional materials enables the scalable fabrication of 3D microrobots using planar processing techniques, demonstrating significant potential in fields such as biological micromanipulation. In this talk, I will first introduce a novel micro-actuator based on electrochemical reactions. By integrating origami design principles, we have developed a highly integrated micromanipulation robot system with multi-modal motion capabilities. Next, I will present in vivo sensing technologies for microrobots, including mechanical sensing, biochemical sensing, and others. Finally, I will discuss typical applications of these microrobots, such as cell manipulation and conformal sensing. Looking ahead, this technological platform holds broad prospects for precision medicine applications, including minimally invasive surgery and in situ biosensing.